Botiman
Home / decision brief

Object retrieval

Find and carry common household objects from variable locations.

3evaluated candidates1documented deploymentsE3 INDEPENDENT DEMOIndependent demonstration
What this task requires

The recorded constraints

Reach M
1.5
Autonomy
supervised
Mobility
indoor
Payload Kg
5
Perception
open-world vision
Manipulation
high
Duration Hours
4
Human Interaction
true
Before choosing

What to verify

  • Verify Reach M meets the recorded requirement of 1.5 in the proposed operating environment.
  • Verify Autonomy meets the recorded requirement of supervised in the proposed operating environment.
  • Verify Mobility meets the recorded requirement of indoor in the proposed operating environment.
  • Verify Payload Kg meets the recorded requirement of 5 in the proposed operating environment.
  • Verify Perception meets the recorded requirement of open-world vision in the proposed operating environment.
  • Verify Manipulation meets the recorded requirement of high in the proposed operating environment.
  • Verify Duration Hours meets the recorded requirement of 4 in the proposed operating environment.
  • Verify Human Interaction meets the recorded requirement of true in the proposed operating environment.
  • Compare the assessment evidence level and notes with the conditions of your site.
  • Public pricing is not available for every evaluated robot.
How Task Match works →
Primary decision section

Robots evaluated for this task

Scores and ordering are BotimanΓÇÖs stored task assessments. They are evidence-informed signals, not guarantees of universal task performance.

Independent decision support

Specialized alternatives to consider

The task record identifies these specialized alternatives. A humanoid is not automatically the best answer for structured work.

Field record

Deployment evidence

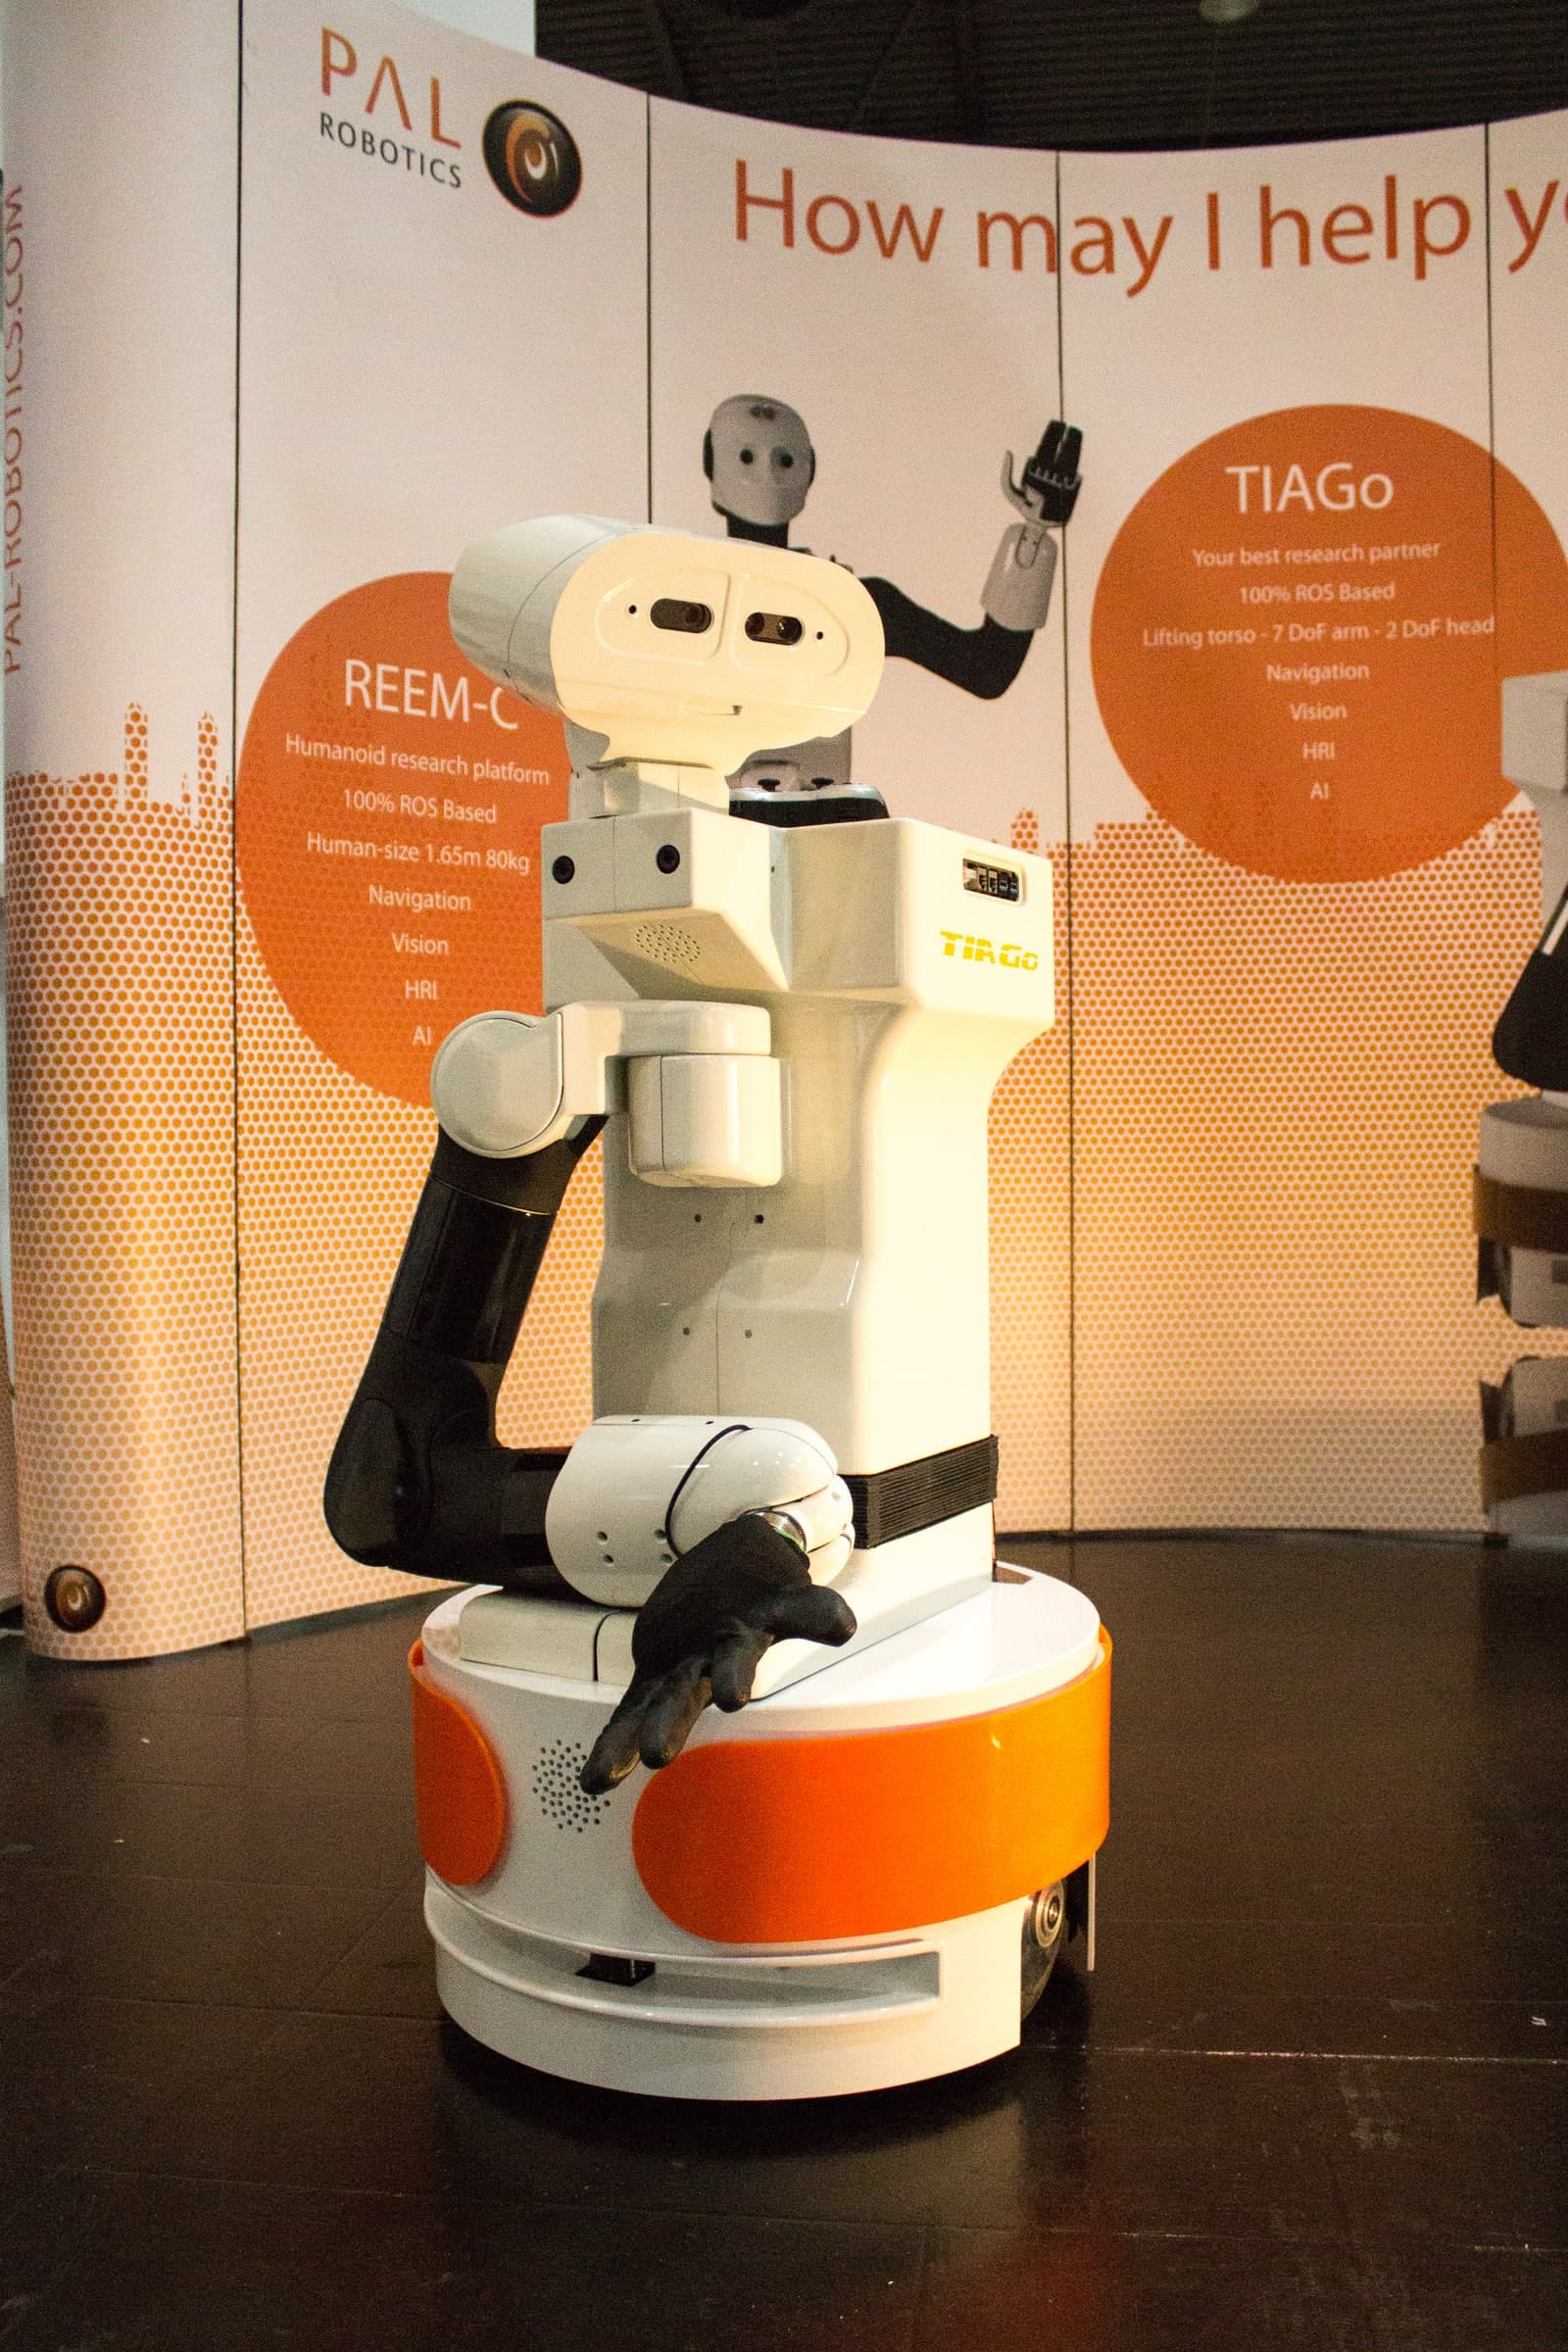
TIAGowithOpenDR research consortium
research demonstration

Research manipulation and navigation ┬╖ European Union ┬╖ Historical research project

Named research project reference; no production outcome claimed.

Autonomy S U P E R V I S E D A U T O N O M YSupervision Research supervisionEvidence E3 INDEPENDENT DEMOIndependent demonstrationAnnounced Date not publicly disclosed
PAL Robotics source Γåù
Evidence gaps

What remains uncertain